# Drive System
## Driving Motors (CubeMars)
Each of the 6 driving motors requires power and data (CAN and UART) routed from inside the chassis of the rover.
### Power
Power is delivered over a black (–) and a red (+) wire. These wires run through the interior of the aluminum extrusions and terminate in a female XT-60 connector at each of the wheels.
Each motor connects to this system via a short power cable with:
- **Male XT-30** on one end — plugs into the motor
- **Male XT-60** on the other end — plugs into the rover's female XT-60 connector
### Data
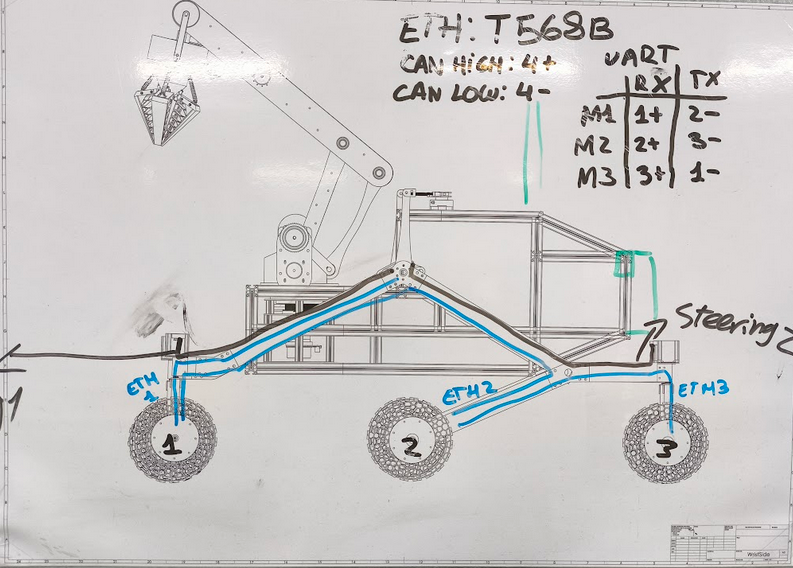
Data is carried over Ethernet cables and connectors, wired to the **T568B** standard.
Each wheel has one Ethernet-in and one Ethernet-out connector, **except** the back wheels, which have an Ethernet-in and a terminator (a 120Ω resistor) in place of Ethernet-out.
**Motor numbering:**
| Position
| Motor ID
|
|---|
| Front wheels
| M1
|
| Middle wheels
| M2
|
| Back wheels
| M3
|
**Cable layout (per side, 3 cables total):**
| Cable
| Run
|
|---|
| Cable 1
| Chassis → Front wheel
|
| Cable 2
| Front wheel → Middle wheel
|
| Cable 3
| Middle wheel → Back wheel
|
[](https://bookstack.roboteamtwente.nl/uploads/images/gallery/2026-07/WHgimage.png)
#### Ethernet Connector Pinouts
Each wheel has two female Ethernet connectors: one **in**, one **out**. Pin assignments below follow T568B pairing (pins grouped by pair: 1–2, 3–6, 4–5, 7–8 in standard Ethernet), but here shown per the rover's female connectors labeling.
**M1 – In**
| Pin
| +
| –
|
|---|
| 1
| RX
| M1 out 1–
|
| 2
| M1 out 2+
| TX
|
| 3
| M1 out 3+
| M1 out 3–
|
| 4
| CAN HIGH 1
| CAN LOW 1
|
**M1 – Out**
| Pin
| +
| –
|
|---|
| 1
| —
| M1 in 1–
|
| 2
| M1 in 2+
| —
|
| 3
| M1 in 3+
| M1 in 3–
|
| 4
| CAN HIGH 2
| CAN LOW 2
|
**M2 – In**
| Pin
| +
| –
|
|---|
| 1
| M2 out 1+
| M2 out 1–
|
| 2
| RX
| M2 out 2–
|
| 3
| M2 out 3+
| TX
|
| 4
| CAN HIGH 2
| CAN LOW 2
|
**M2 – Out**
| Pin
| +
| –
|
|---|
| 1
| M2 in 1+
| M2 in 1–
|
| 2
| —
| M2 in 2–
|
| 3
| M2 in 3+
| —
|
| 4
| CAN HIGH 3
| CAN LOW 3
|
**M3 – In**
| Pin
| +
| –
|
|---|
| 1
| —
| TX
|
| 2
| —
| —
|
| 3
| RX
| —
|
| 4
| CAN HIGH 3
| CAN LOW 3
|
#### Motor-Side Connection
The female Ethernet connector cables connect to the motors via **GH connectors**.
**Warning:** The GH-side connector should **never** be disconnected from the motor. This connector sits inside the motor driver and is physically flimsy — one driver has already been bricked from being connected/disconnected too many times.
## Steering motors
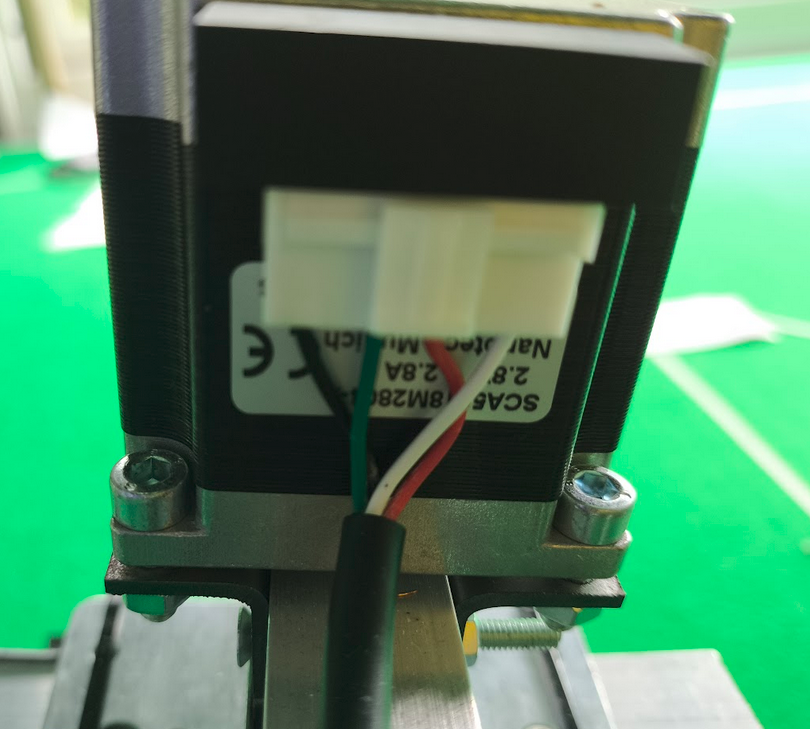
The steering motors are connected through 5-way wire (with one of the channels cut off) to the motor drivers.
[](https://bookstack.roboteamtwente.nl/uploads/images/gallery/2026-07/54Gimage.png)[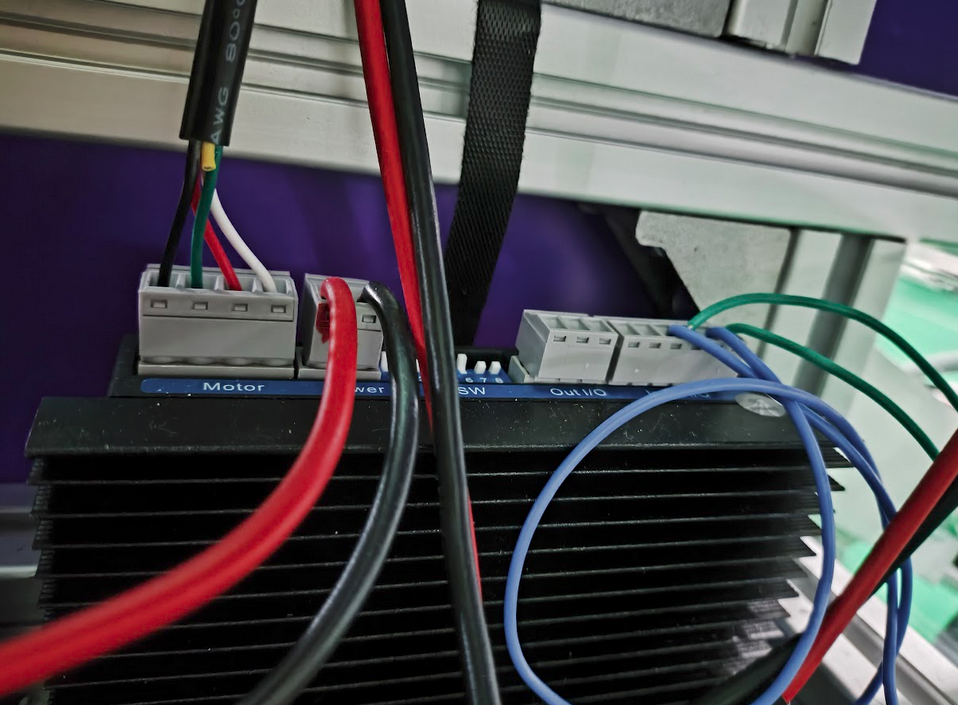](https://bookstack.roboteamtwente.nl/uploads/images/gallery/2026-07/Mdaimage.png)